Project
Robotic 2×2 Cube Solver
Rubik's Cube Solver
In ProgressA stepper-and-servo robot that turns a 2×2 cube.
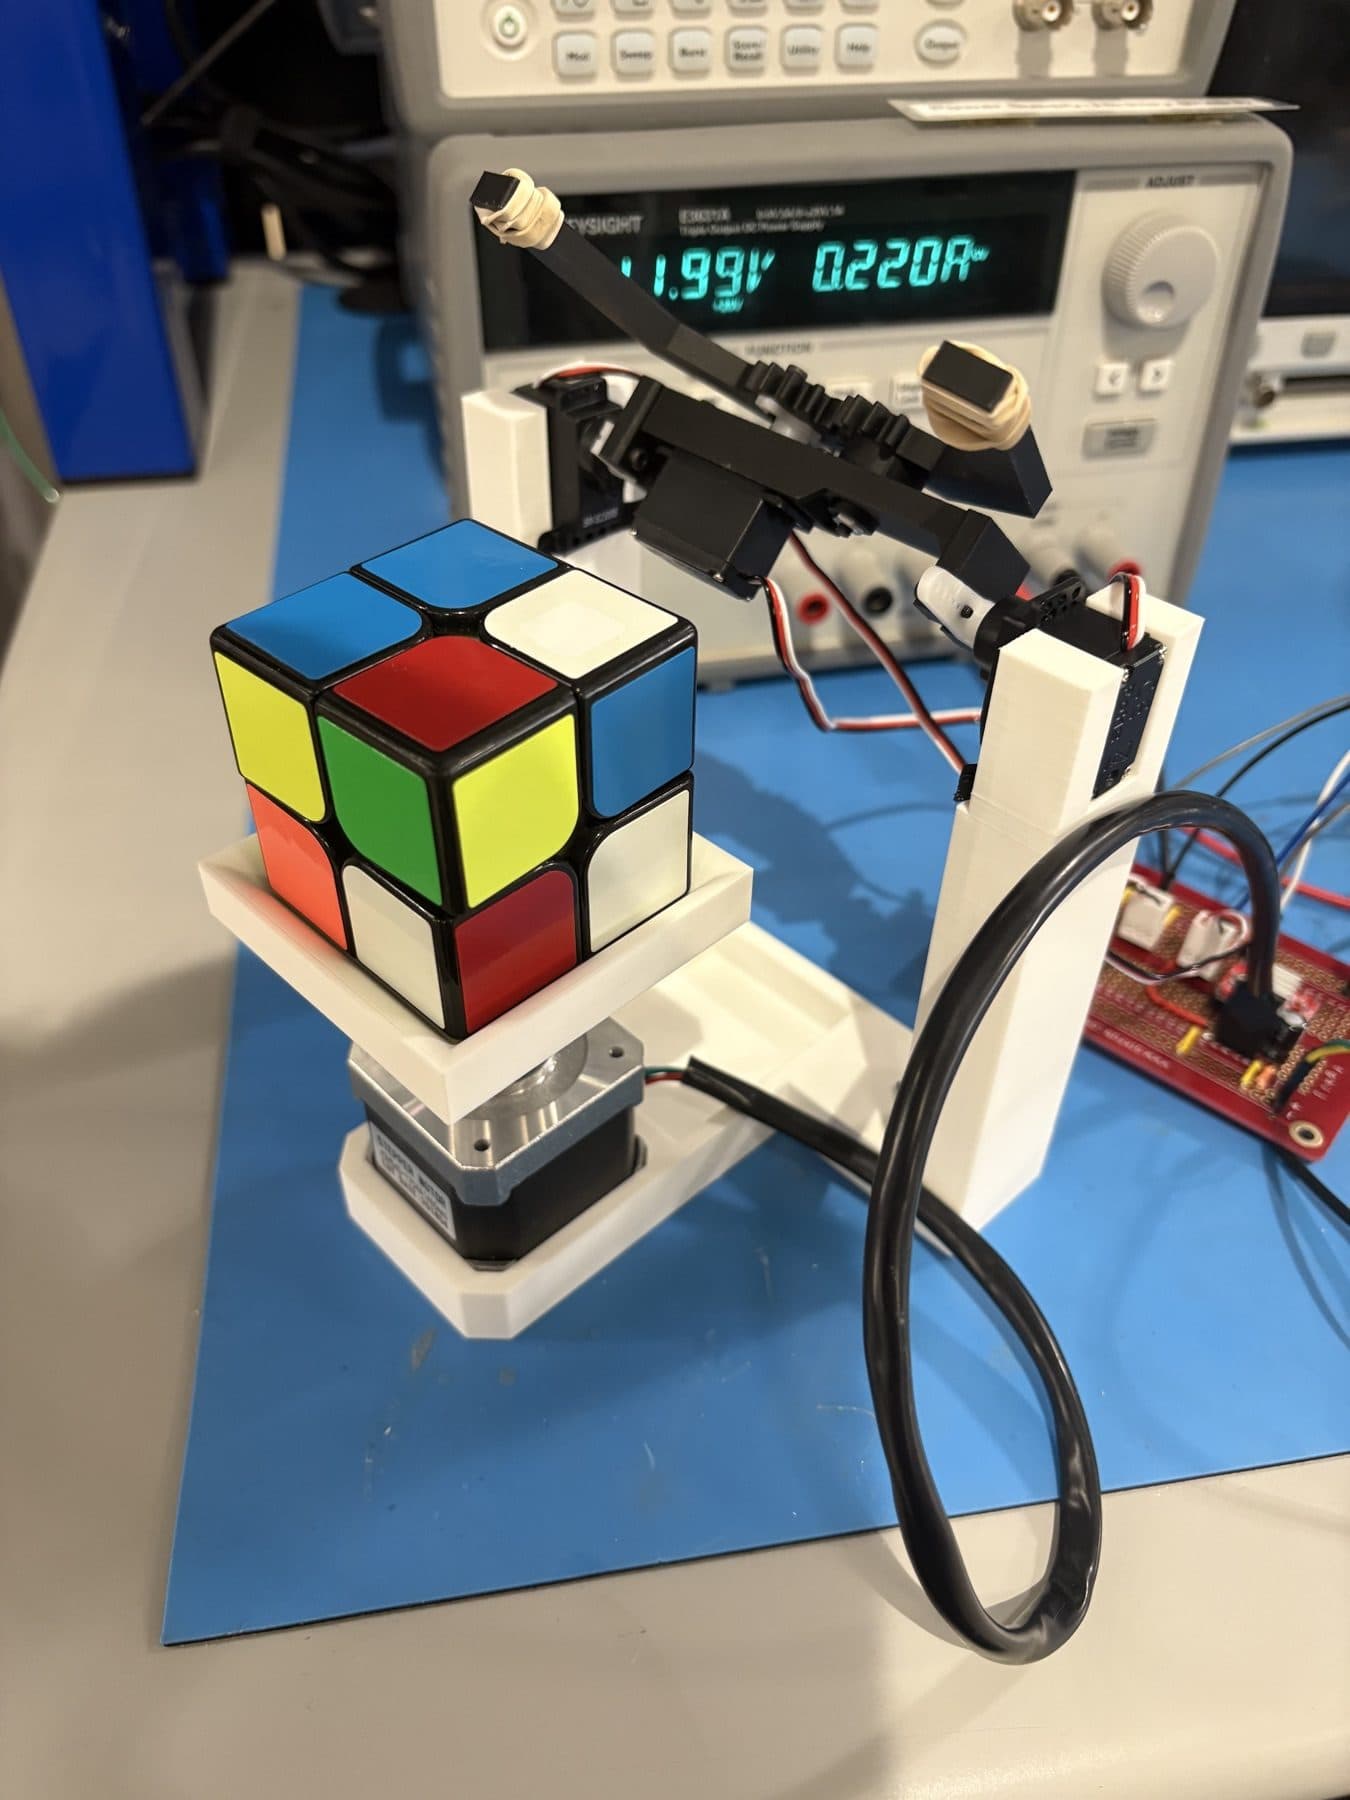
A robot that executes cube moves one by one, turning the bottom layer on a stepper-driven turntable and flipping the cube with a servo-driven claw arm to bring each face into position.
- Status
- In Progress
- Built with
- C++ArduinoAccelStepperStepper MotorServos3D Printing
The mechanism
Turn, grip, flip.
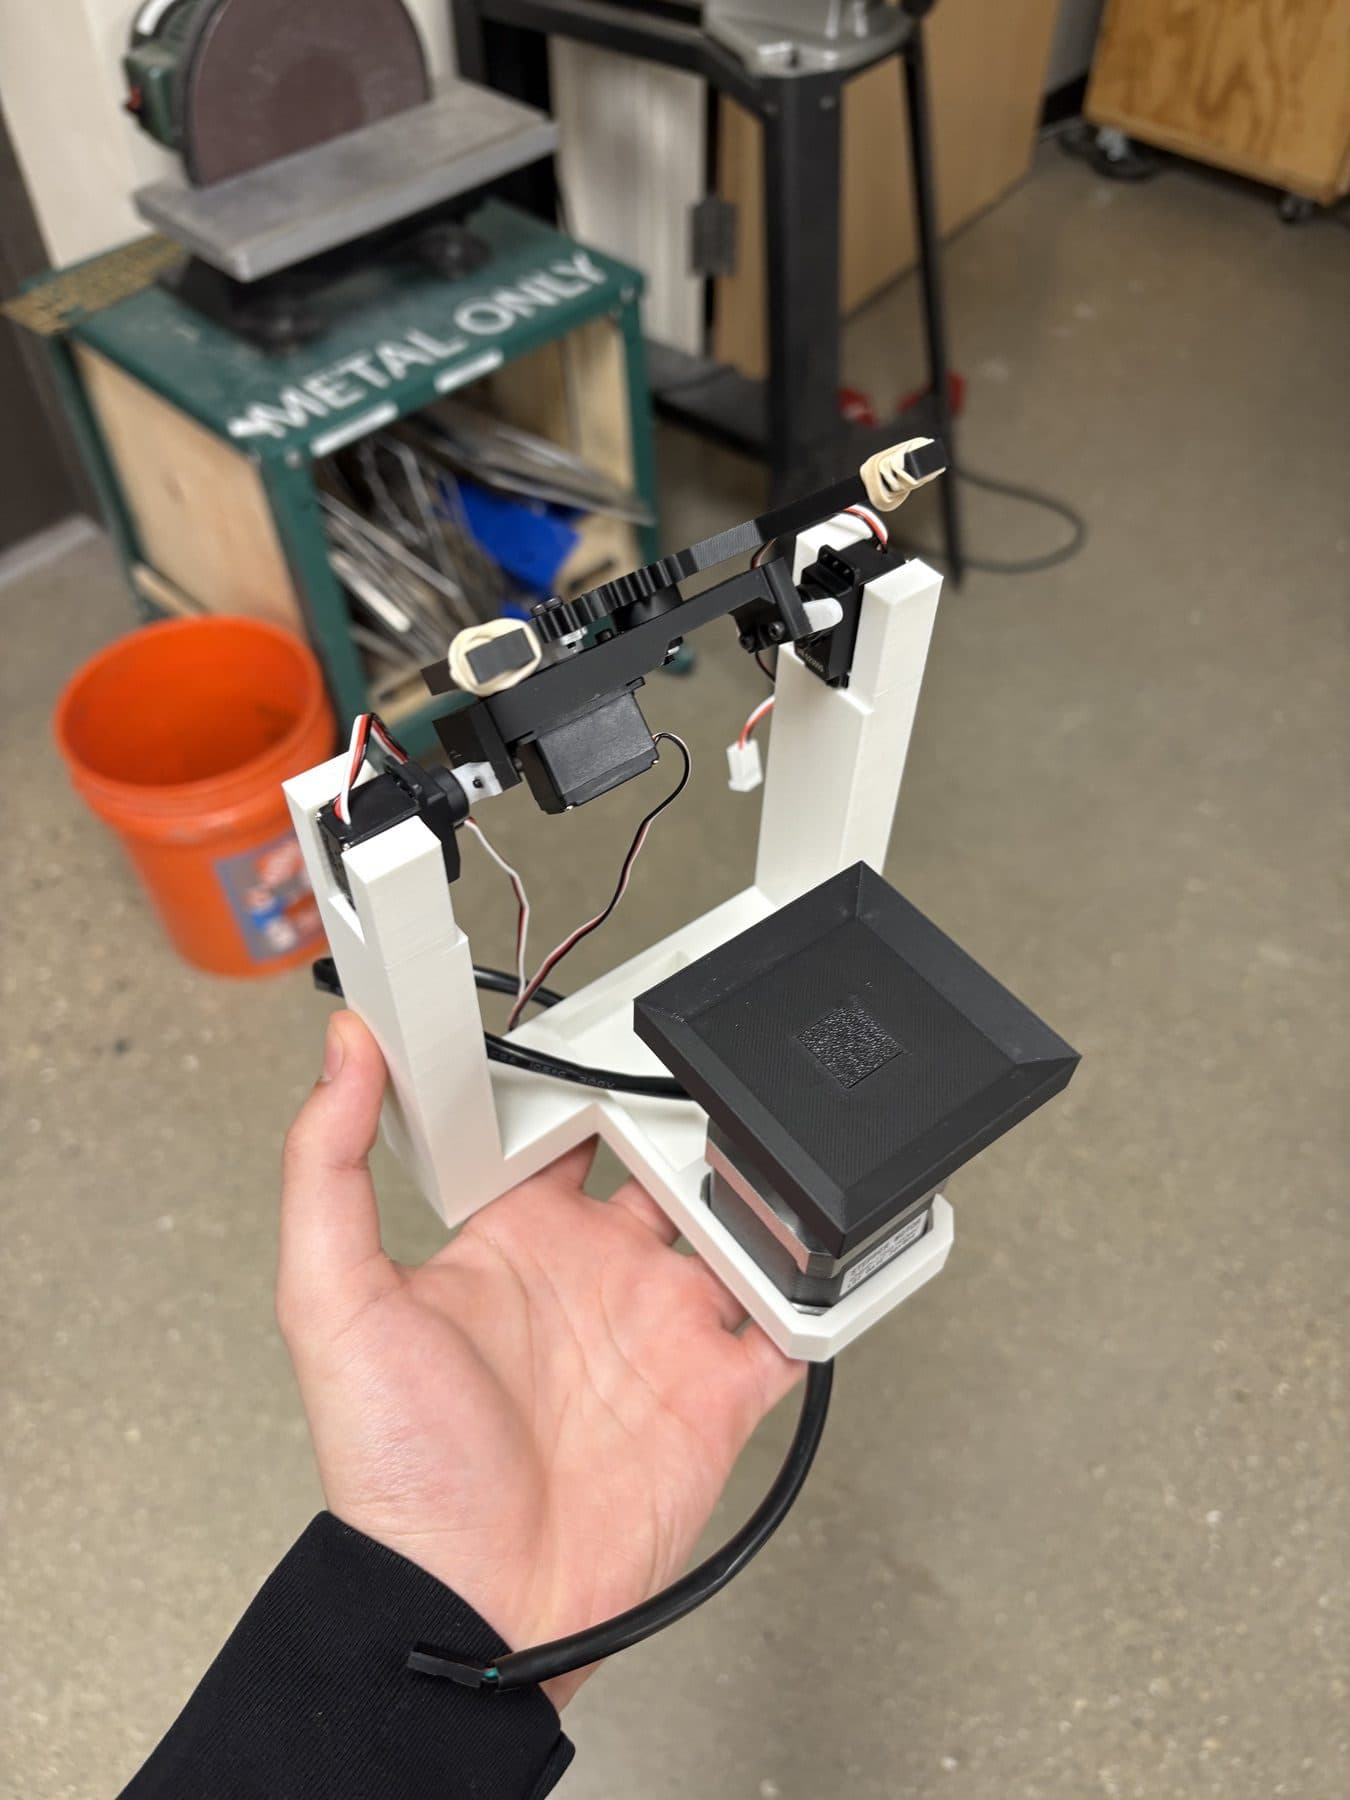
A stepper motor spins a turntable under the cube. Above it, two mirrored servos tilt an arm and a third closes its claw. The arm either holds the upper layer still while the turntable twists the bottom one, or pulls the whole cube over to bring a new face down.
The firmware
Every face, from the bottom.
The Arduino executes any move sequence in standard cube notation (R1 U1 F1 …). The robot can only ever turn the bottom face, so the firmware tracks the cube's orientation through every flip and spin, and works out the regrips needed to bring each face to the turntable before turning it.
What's next
From executing moves to solving.
The robot can already carry out any move sequence. Next up:
- Connecting the scrambling code to a solver algorithm, so the robot works out its own solution
- Redesigning some of the 3D-printed parts for more stability
Next
ECG Signal Processing & Edge ML
On-device machine learning for ECG signals.